JULY 2026 TO PRESENT · TORONTO, CA
Hi, I’m
Matthew Sakhno
Toronto → Paris
Originally from Toronto and currently studying electrical and mechanical engineering at Sorbonne Université in Paris, I build robotics, embedded systems, and hardware reliable enough to ship.
ResumeElectronics & embedded systemsPCB design · KiCad/Altium · STM32/ESP32 · power electronics · controlled-impedance routing
Robotics & autonomyROS 2 · SLAM · computer vision · sensor fusion · motion control
Mechanical design & prototypingCAD/Onshape · DFM · rapid prototyping · electromechanical integration · test infrastructure
Industrial systems & softwareEtherCAT · Modbus · embedded Linux · Python/C++ · FastAPI
Projects
View case study
 View case study
 View case study
 View case study
 View case study
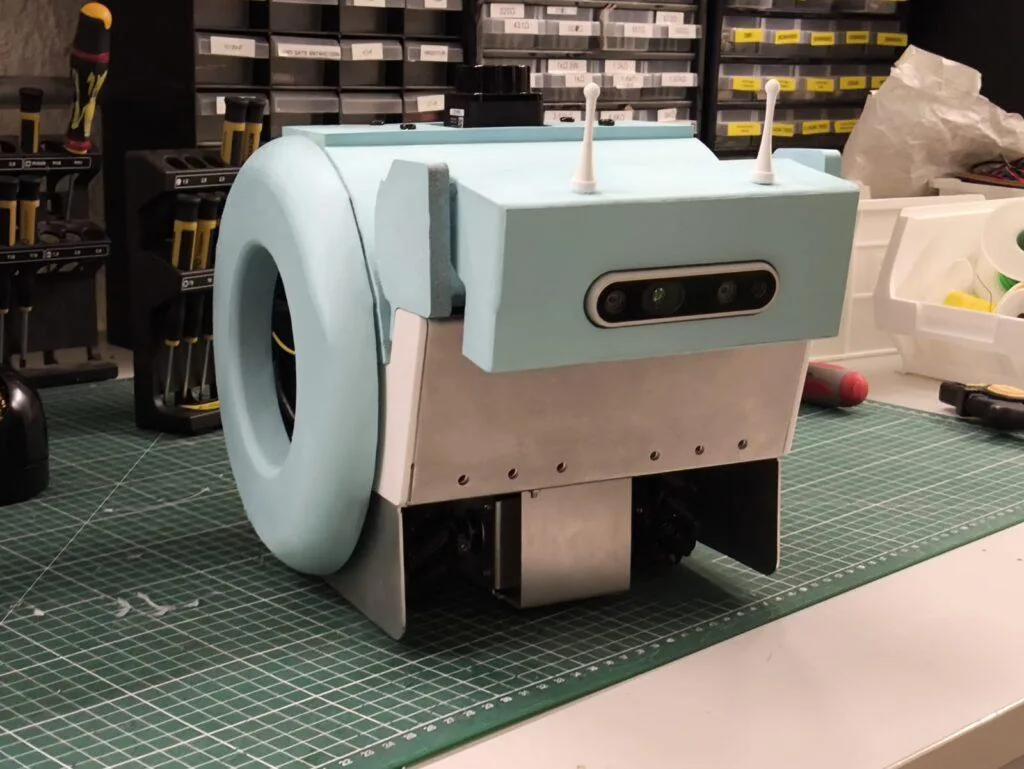
Autonomous edge AI2025 ↗
snAI-l: Autonomous Edge AI Robot for Education
An educational AI robot integrating Jetson, ESP32, sensing, motion, and a complete software stack.
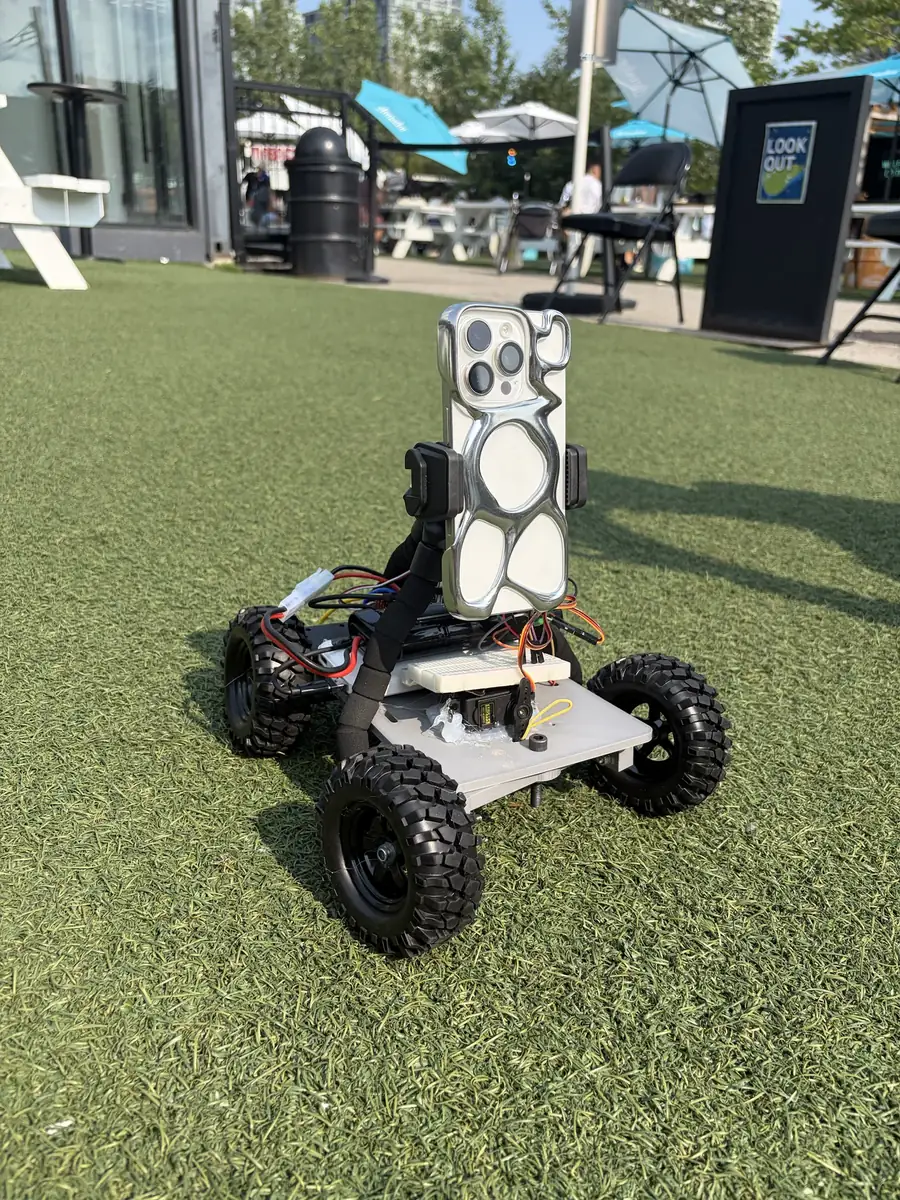
Hackathon winner · ~150 hackers2026 ↗
Spark Rover — 1st Place at SummerHacks
A 24-hour ESP32 rover integrating motor drive, servo steering, custom wiring, CAD, FDM fabrication, and spatial capture.
Embedded robotics2025 ↗
Jetson + ESP32 Robotics Control Platform
Custom electronics tying battery management, compute, motor actuation, protection, and serviceability into one reliable platform.
High-speed PCB design2026 ↗
High-Speed AUV Interface PCB
High-speed differential signalling and robust control in a compact form factor.
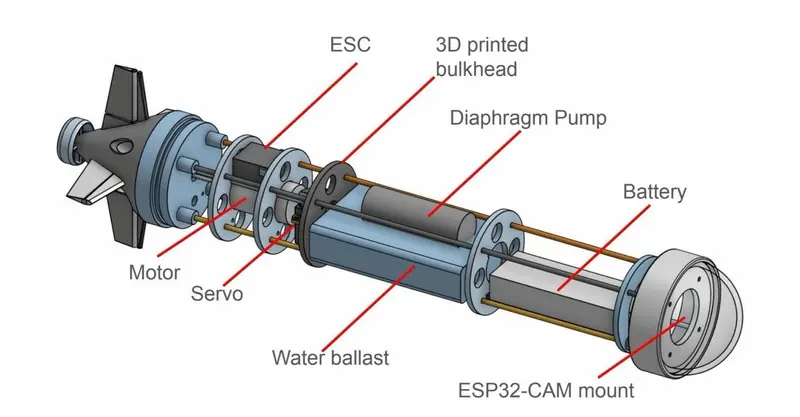
Underwater robotics2026 ↗
Modular AUV Designed for 15-Meter Depth
A system-level build spanning sealed mechanics, sensing, propulsion, embedded control, and maintainable subsystem architecture.
About Matthew Sakhno

Robotics is where everything I enjoy about engineering comes together.
I grew up in Toronto and moved to Paris to study electrical and mechanical engineering at Sorbonne Université. I gravitated toward robotics because it turns those disciplines into one real system: the electronics have to survive, the mechanism has to fit, and the software has to make the whole system useful.
I'm at my best when I can follow a problem across those boundaries, learn what I'm missing, and turn an early prototype into hardware that is easier to test, repair, and trust. That's the kind of work I want to keep doing with a team building ambitious physical products.
Verified profiles for Matthew Sakhno: LinkedIn, GitHub, Instagram, Devpost, and ISIR.
Currently studying · Paris, France
Sorbonne Université
BSc Electrical and Mechanical Engineering · Expected 2027
Part of Sorbonne's selective CMI EEA, an intensive five-year engineering track with additional coursework, annual projects, four internships, and research-backed training.
Cross-disciplinaryElectronics, mechanics, software
Production-mindedTestable, serviceable, documented
English + FrenchNative · Fluent
Toronto + ParisWorked and studied internationally
Experience
JUNE TO AUGUST 2025 · PARIS, FR
Robotics Engineering Intern · ISIR
AI education robotics platform
- Designed the electrical architecture and core software for a Jetson-powered educational AI robot, coordinating mechanical and AI integration and documenting system decisions.
- Designed, assembled, and tested a four-layer ESP32 PCB for four stepper motors, odometry, Jetson UART communication, soft shutdown, battery management, and USB-C charging.
- Integrated Intel RealSense, 360° LiDAR, and wheel encoders; deployed RTAB-Map SLAM in ROS2 for localization, obstacle awareness, autonomous navigation, and 3D mapping.
- Deployed YOLOv8 and NanoOWL for real-time object and marker recognition and built a Python/FastAPI Scratch-style interface for no-code robot programming.
JUNE TO AUGUST 2024 · TORONTO, CA
Network and Systems Intern · Green Clean
Remote operations + infrastructure
- Developed embedded Linux edge devices using Raspberry Pis and custom Bash scripts to process and stream real-time data across distributed field sites.
- Architected a remote telemetry network from scratch, integrating 4G modems and persistent Cloudflare tunnels to ensure reliable, off-grid connectivity for remote hardware.
- Executed the electromechanical assembly and integration of remote monitoring hardware, including low-voltage cable routing, component mounting, and network configuration.
- Deployed and synchronized centralized hardware systems across multiple remote worksites to automate field operations and data tracking.